Robotics and Control, All Along
I am a researcher and engineer in the Humanoid Department at Galbot, directed by Prof. Li Yi, based in Beijing. Previously, I received my MSc in Systems and Control from TU Delft (2025), supervised by Niels van Duijkeren and Tamas Keviczky, and my BSc in Automation from Beijing Institute of Technology (2022), advised by Wenjie Song.
My earlier works centered on low-level motion control for humanoid robots. The question I now care about goes further: how humanoid robots become intelligent enough to carry out whole-body loco-manipulation tasks. Specifically, I am interested in behavior foundation models, VLA / WAM, and how the two can be orchestrated to jointly accomplish tasks for humanoid.
I bring together two distinct yet complementary backgrounds: model-based numerical methods and learning-based approaches. At TU Delft, I developed optimization solvers for model predictive control; at Galbot, I now mainly use reinforcement learning to tackle a broader range of challenging whole-body tasks.
News
- Jun 2026 — HumanTracker accepted to ECCV 2026.
- Jun 2026 — LATENT (humanoid tennis) accepted to IROS 2026.
- May 2026 — LIMMT accepted to ICML 2026.
- Mar 2026 — Humanoid-GPT accepted to CVPR 2026 (co-first author).
- Jan 2026 — Any2Track accepted to ICRA 2026.
- Sep 2025 — Joined Galbot full-time, Humanoid Department (intern since Jun 2025).
- Feb 2025 — Completed MSc in Systems and Control at TU Delft.
- Jun 2022 — Completed BSc in Automation (XuTeli Elite) at Beijing Institute of Technology.
Publications
Conference Papers
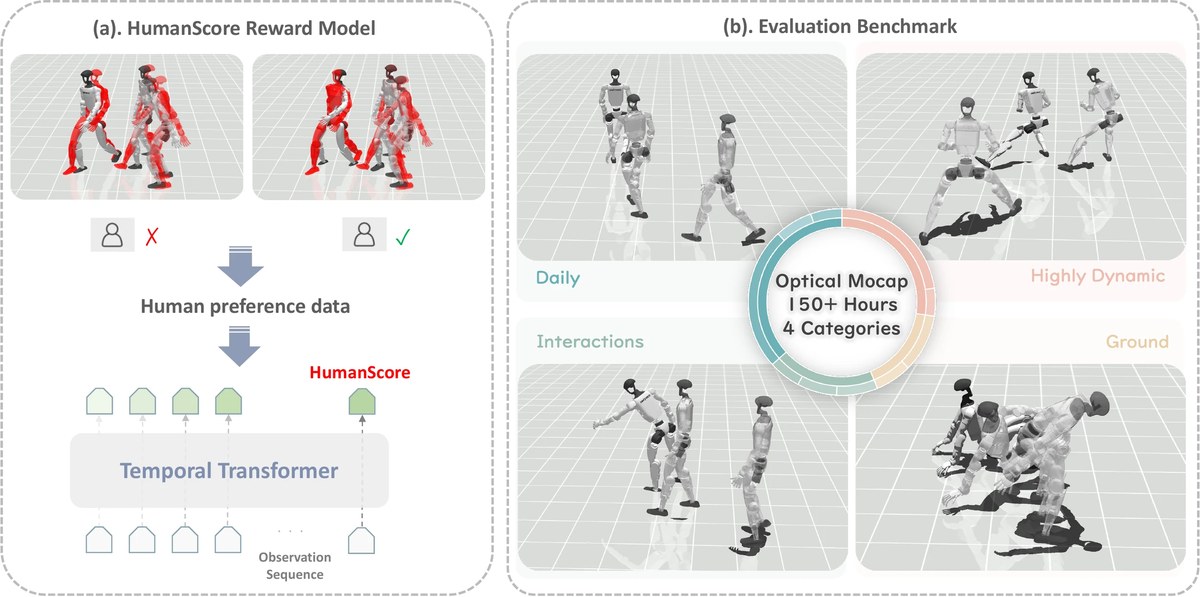
HumanTracker: Towards Comprehensive and Human-Aligned Motion Tracking Benchmark
European Conference on Computer Vision (ECCV), 2026
A benchmark for humanoid motion tracking that aligns evaluation with human perception, capturing the physical artifacts that kinematic error metrics miss.
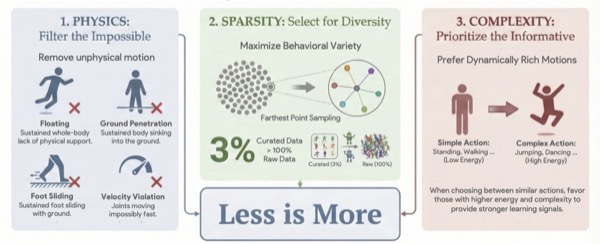
LIMMT: Less is More for Motion Tracking
International Conference on Machine Learning (ICML), 2026
Paper / arXiv / Project Page
The first data-centric study for physics-based humanoid motion tracking: high-quality motion data steers tracking policies toward better optimization trajectories.
Humanoid-GPT: Scaling Data and Structure for Zero-Shot Motion Tracking
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026
arXiv / Project Page / Code
A GPT-style Transformer trained on a billion-scale motion corpus for whole-body control, achieving zero-shot generalization to unseen motions and control tasks.
Learning Athletic Humanoid Tennis Skills from Imperfect Human Motion Data
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
arXiv / Project Page / Code
LATENT constructs a latent action space from imperfect human motion data, enabling the Unitree G1 to sustain multi-shot tennis rallies with human players.
Track Any Motions under Any Disturbances
IEEE International Conference on Robotics and Automation (ICRA), 2026
arXiv / Project Page / Code
Any2Track tracks diverse, highly dynamic, contact-rich motions under terrain changes, external forces, and payloads, via a dynamics world model for policy fine-tuning.
Yes, that's me kicking the robot 🦵🤖
Preprints
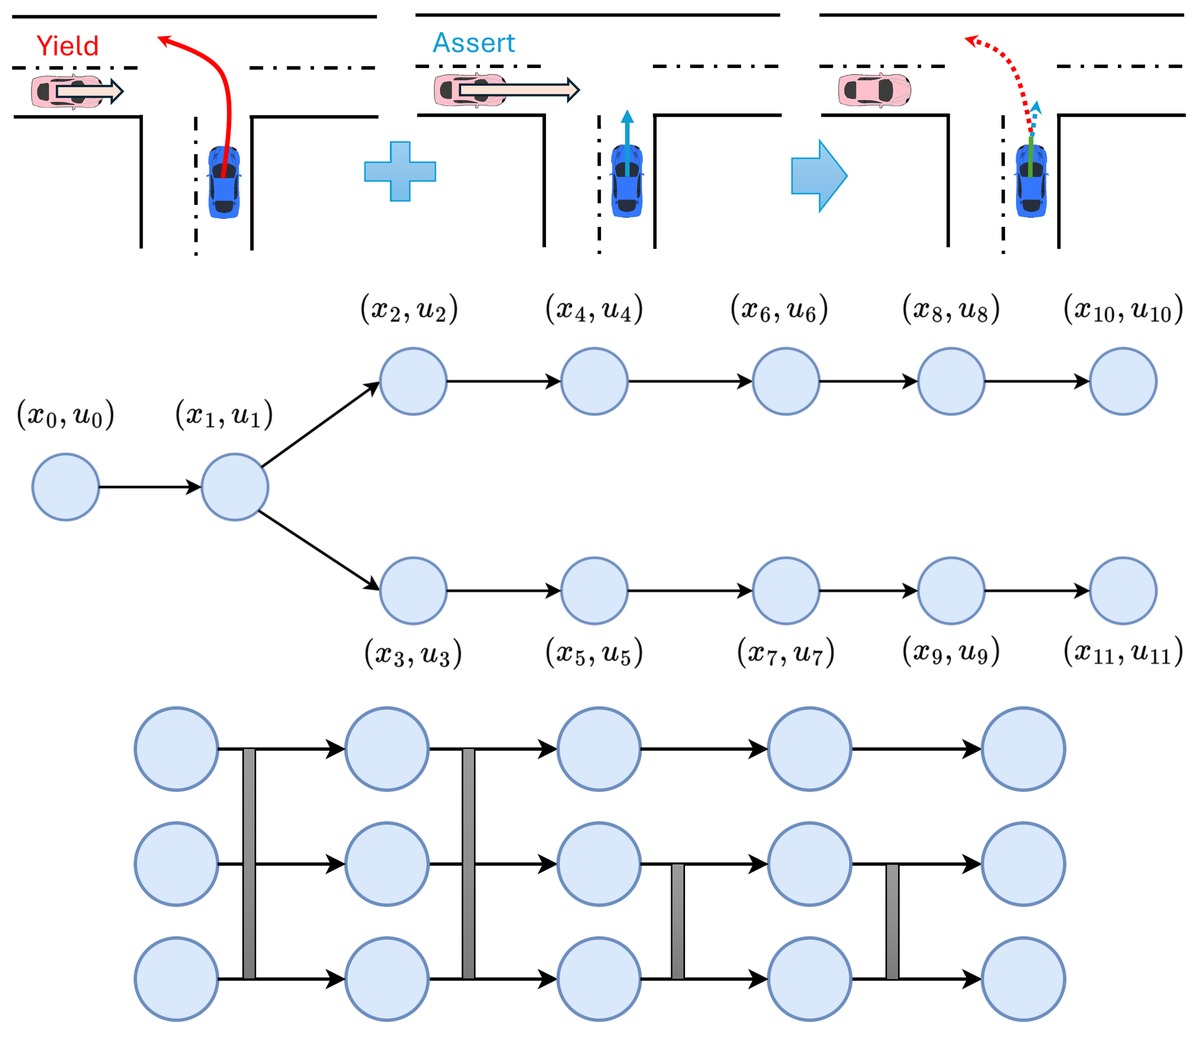
Parallel Branch Model Predictive Control on GPUs
arXiv preprint arXiv:2506.13624, 2025 · submitted to IEEE T-CST
A GPU-accelerated iLQR solver for branch MPC exploiting tree-sparse structure with parallel-scan temporal parallelism, enabling parallelism across both prediction horizon and scenarios.
* indicates equal contribution
Also on my Google Scholar profile.
Education
MSc, Systems and Control · Delft University of Technology · 2022 – 2025
Faculty of Mechanical Engineering, Delft Center for Systems and Control (DCSC).
Thesis: efficient numerical inequality-constrained MPC on matrix Lie groups — developed a C++/Python solver for constrained trajectory optimization on manifolds.
BSc, Automation · Beijing Institute of Technology · 2018 – 2022
Xu Teli Elite Class. Graduated with honors.
Thesis: active compliant landing control for bipedal robots — staged compliance control for high-drop impact attenuation, validated in simulation and on hardware.
Work Experience
Galbot · Humanoid Department · Beijing · Sep 2025 – present
Researcher & engineer, reinforcement learning for motion control. Motion capture retargeting via numerical optimization; whole-body tracking controllers for dance, acrobatic, and teleoperated motion; large-scale motion dataset curation and cleaning tooling.
Galbot · Humanoid Department · Beijing · Jun – Sep 2025
Research assistant to Prof. Li Yi, and intern at Galbot.
Forze Hydrogen Racing · Simulation & Control · Delft · 2023 – 2024
Modeling, system identification, and state estimation for the supercapacitor energy store. The state-of-charge estimator I built runs onboard the team's ninth-generation car.
Contact
Reach me at chenghuailin65@gmail.com. I am always glad to talk about humanoid, robotics, optimization, geometry, and anything that has to move in real time.